Choosing the right Coupling Drive Motor in 2026 is not simply a matter of selecting the highest horsepower. The motor must match the coupling, driven load, operating cycle, installation space, and maintenance capability. A conveyor moving wet aggregate needs different protection from a precision packaging line. Small mismatches can create heat, vibration, and premature bearing failure.
Heinz P. Bloch, a respected rotating-equipment reliability engineer, stated, “Reliability is designed in, not inspected in.” That principle remains highly relevant. Begin with measured torque and starting demand, not assumptions from an old equipment label. Check rated speed, overload capacity, service factor, shaft dimensions, and coupling misalignment limits. A variable-frequency drive may improve control, but it can also introduce harmonic heating and bearing-current risks. Proper grounding and compatible insulation are essential.
The installation environment deserves equal attention. Dust, washdown water, high ambient temperatures, and frequent starts can change the motor selection completely. An IP-rated enclosure, suitable cooling method, and correct lubrication plan may matter more than a small efficiency gain. IE4 efficiency is attractive, yet the complete system should be evaluated, including the drive and coupling losses. Numbers can mislead.
A practical selection also includes future maintenance. Can technicians access the motor safely? Are spare bearings and seals available locally? Will alignment remain stable after thermal expansion? These questions expose weaknesses early. I would not pretend every application has a perfect answer. Field measurements can be incomplete, and operating habits often differ from design documents. Therefore, validate the final Coupling Drive Motor choice through load testing, vibration monitoring, and a documented commissioning review.
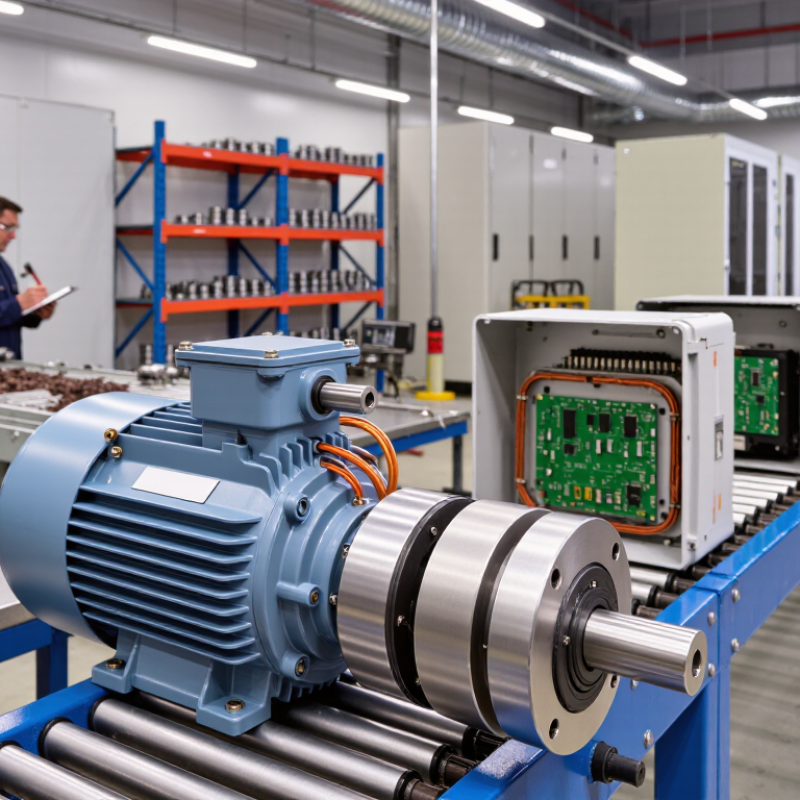
Define the load before comparing motor ratings. Measure torque, speed, acceleration, starts per hour, and running time. Use T = 9550P/n, where T is torque in newton-metres, P is power in kilowatts, and n is speed in revolutions per minute.
For example, a 15 kW load at 1,450 rpm needs about 99 Nm before acceleration and losses. Coupling stiffness, shaft misalignment, and gearbox efficiency can increase the required torque.
IEC 60034-1:2022 requires ratings to reflect operating conditions and thermal performance. Select the duty type carefully, such as S1 for continuous operation or S3 for intermittent loads.
A conveyor running for 12 minutes, stopping for three minutes, and starting 18 times hourly should not be treated like a steady pump. The IEA estimates that electric motors and motor-driven systems consume about 45% of global electricity. Small sizing errors can therefore create meaningful energy waste. Oversizing also deserves attention; it may reduce efficiency at light load.
Tips: Record the real load profile for several shifts. Check peak torque, not only average torque. Leave practical thermal margin, but do not hide uncertainty inside a large service factor. Recalculate after coupling changes. This step is often missed. Growth assumptions can also be wrong. Validate them against measured production data and the motor’s actual duty cycle.
Choosing a coupling drive motor starts with the load, not the catalog rating. Peak torque can appear during startup, sudden jams, product buildup, or repeated reversing. Size only for average load, and the motor may overheat during operation. Measure running torque, starting torque, speed, duty cycle, and coupling alignment. Then apply a 1.15–1.25 service factor to the highest credible peak load. This margin covers brief overloads, measurement error, and normal process variation. It does not replace thermal, electrical, or shaft stress checks.
For example, a conveyor may run smoothly at 8 kW but demand 10 kW during loading. A 1.15 factor suggests 11.5 kW, while a 1.25 factor suggests 12.5 kW. Use the higher factor when peak events are frequent, uncertain, or difficult to measure. However, extra capacity has a cost. An oversized motor can cycle poorly, waste energy, and complicate coupling protection. Early calculations are often too clean. Real equipment rarely behaves perfectly.
Tips: Record peak events with a torque sensor or drive log. Check the motor’s rated duty and starting capability. Confirm coupling alignment after installation. Recheck the estimate when material, speed, or production conditions change. A short measurement session can prevent a costly sizing mistake.
Choosing a coupling drive motor in 2026 starts with its real load profile. IEC 60034-30-1 compares motor efficiency at defined operating points, not every site condition. IE3 remains a sensible baseline for steady industrial duty. IE4 can reduce losses further, especially during long annual running hours. IE5 may offer additional savings, but its purchase cost and control compatibility require careful checking.
The U.S. Department of Energy’s Motor Systems Market Assessment reports that motor systems consume about 68% of industrial electricity. The IEA’s Energy Efficiency 2023 analysis places motor-driven systems near 53% of global electricity use. These figures make small efficiency gains financially meaningful. Still, a higher class does not automatically deliver lower total energy use. Oversizing, poor coupling alignment, frequent starts, and low-load operation can erase expected benefits. Measure shaft load, running hours, power factor, and temperature before selecting the motor. Check the applicable IEC edition, because IE5 recognition and testing boundaries may differ.
Tips: Compare lifetime cost, not only the nameplate price. Record current and voltage during normal production. Inspect coupling alignment with laser tools. Ask whether the motor and variable-speed drive are jointly rated. A useful calculation is annual energy saved multiplied by electricity cost. My practical caution is simple: IE5 can be excellent, but it may be wasteful for lightly loaded equipment. A measured IE3 solution can outperform a poorly specified IE5 installation.
Choosing the right coupling drive motor in 2026 starts with the coupling, not the catalog. Confirm the required shaft torque, then compare it with the coupling’s rated torque. Do not rely on motor nameplate torque alone. Startup, jams, reversing, and variable loads can create damaging torque peaks. Apply a realistic service factor based on duty cycle, starts per hour, temperature, and shock. Peak torque matters.
Speed needs equal attention. Check continuous speed, acceleration speed, and any short-term overspeed. The coupling must remain stable without excessive heat, vibration, or resonance. Confirm angular, parallel, and axial misalignment limits from the technical data. These limits are not permission to ignore alignment. A small offset can grow after installation, thermal expansion, or bearing movement. Measure both shafts carefully.
Tips: Record torque, rpm, load pattern, and ambient temperature before selecting the motor. Keep written alignment readings. Recheck them after a thermal run. Real installations drift. A neat spreadsheet can still be wrong.
A practical selection should survive normal operation and reasonable mistakes. Compare calculated torque with rated and peak coupling limits, then verify the motor’s speed range. Allow space for inspection and replacement. If the application includes frequent starts or sudden load changes, request a torsional analysis from a qualified engineer. This step is often skipped, although it can reveal resonance that ordinary alignment checks miss. When data is uncertain, measure the machine rather than guessing.
Size the coupling by verifying rated torque, operating speed, and allowable misalignment.
The chart uses standard torque calculations for representative industrial motor sizes operating at 1,500 rpm: T = 9550 × P / n, where T is torque in N·m, P is power in kW, and n is speed in rpm. The minimum coupling torque shown applies a 1.5 service factor to the calculated motor torque. Final selection must also confirm the coupling’s continuous speed rating and allowable angular, parallel, and axial misalignment.
Choosing the Right Coupling Drive Motor in 2026
A coupling drive motor must match the VFD, load profile, and operating environment. Start by checking the VFD’s continuous current, overload capacity, output frequency, and minimum speed limits. A motor may have the correct rated power but still fail under repeated acceleration. Couplings also transmit shock loads from pumps, conveyors, or compressors. Measure the starting torque carefully. Do not guess.
Protection details matter in real installations. An IP rating suitable for a clean workshop may be inadequate near dust, washdown water, or outdoor condensation. Check the complete assembly, not only the motor nameplate. Confirm cable glands, cooling airflow, and enclosure seals. Heat matters. I have seen motors protected correctly on paper but overheated because ventilation was blocked. That experience changed how I review installation drawings.
Tips: Match the motor duty to its actual cycle. S1 means continuous operation, while S2 covers short-time duty. S3 to S8 describe intermittent, cyclic, or specialized operation, and S9 allows non-periodic load changes. S10 addresses operation with distinct constant loads. Compare these classes with starts per hour, running time, braking, and load peaks. Ask for thermal data when the application changes speed frequently. A small mismatch can reduce service life. Recheck the selection after commissioning; field conditions often differ from the original estimate.
Measure torque, speed, acceleration, starts per hour, and operating time. Record the real load across several shifts. Do not rely only on catalog ratings.
Use T = 9550P/n. T is torque in newton-metres, P is power in kilowatts, and n is revolutions per minute. A 15 kW load at 1,450 rpm needs about 99 Nm. Acceleration and losses require additional torque.
Peak torque appears during startup, jams, buildup, and reversing. A conveyor may run at 8 kW but demand 10 kW while loading. Average values can hide overheating risk. Measure the difficult moments.
Apply a 1.15–1.25 factor to the highest credible peak load. For a 10 kW peak, the result is 11.5–12.5 kW. Use the higher factor when events are frequent or uncertain. A large margin is not a substitute for proper checks.
Yes. It may operate inefficiently at light load, cycle poorly, and increase coupling stress. Extra capacity also raises cost. Bigger is not automatically safer.
Compare the duty class with running time, stops, starts per hour, braking, and load peaks. S1 suits continuous operation. S3 suits intermittent cycles. A conveyor running 12 minutes and stopping three minutes needs careful review.
Check continuous current, overload capacity, output frequency, minimum speed, and repeated acceleration capability. Confirm the motor’s starting performance. A correct power rating can still fail during frequent acceleration.
Match the protection level to dust, washdown water, and outdoor condensation. Check cable glands, cooling airflow, and enclosure seals. Blocked ventilation can overheat a correctly selected motor. Paper protection is not enough.
Recalculate after changing the coupling, material, speed, or production rate. Confirm alignment after installation. Compare assumptions with measured production data. The original estimate may be wrong. Recheck after commissioning.
Choosing the right Coupling Drive Motor in 2026 begins with accurately defining the application load. Calculate the required torque, operating speed, acceleration demands, and duty cycle in accordance with IEC 60034-1. Motor power should be selected for normal operation while allowing a 1.15–1.25 service factor to handle peak loads without excessive heating or premature failure. Efficiency is also important: compare IE3, IE4, and IE5 motors based on operating hours, energy costs, and the expected return on investment under IEC 60034-30-1.
The coupling must be sized to withstand the motor’s rated and peak torque, speed, and allowable misalignment. Before final selection, confirm compatibility with the variable-frequency drive, including frequency, current, starting, and braking limits. Check the required IP protection rating for the installation environment, and verify whether the motor’s S1–S10 duty classification matches the actual operating pattern. A properly matched motor, coupling, and control system improves reliability, energy performance, and service life.
Lite Simo